Cable-driven

parallel

robots

serving industry

From the laboratory to the field, TITANBOT develops novel robotic solutions to meet industrial challenges. The project aims to transfer scientific advances in cable-driven parallel robots to practical applications in the construction and nuclear sectors, with a core objective: improving productivity, safety, and working conditions.

Cable-driven parallel robots offer a unique combination: high payload capacities, large workspaces, and mechanical simplicity. TITANBOT works to overcome their key bottlenecks—accuracy, ease of deployment, safety, and accessibility—to make them directly deployable in the field, including by operators who are not robotics specialists.
TITANBOT
at a glance

0 months

duration for Phase 1 of the project, dedicated to technology assessment and maturation.

0 partners

brought together around the CNRS, covering the entire value chain, from research to industrial end-users and technological integration.

0 use cases

Construction & nuclear, with applications developed in collaboration with VINCI Energies and Orano DS.

0 kg

targeted payload capacity for the robot intended for construction sites, with a workspace ultimately reaching up to 40 × 30 m.

Two applications,

a single objective

Two applications,

a single objective

Building differently

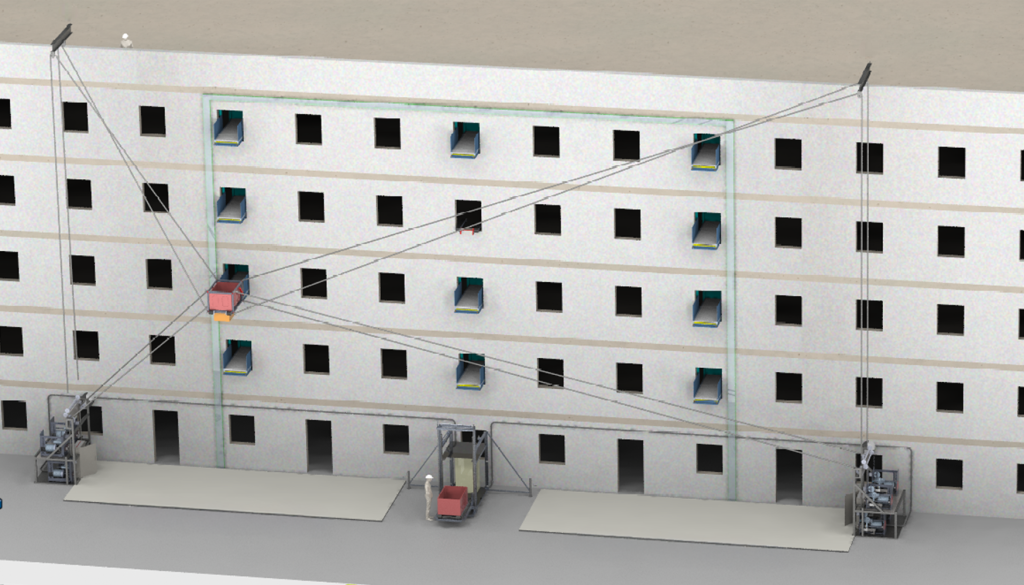
On construction sites, TITANBOT is developing with VINCI Energies a cable-driven parallel robot capable of transporting materials up to 100 kg along building facades.

Autonomous and designed to operate alongside workers, it is intended to reduce manual handling and streamline material delivery to upper floors.

Objective: reduce physical strain and improve working conditions on construction sites.

Remote inspection

For Orano DS, TITANBOT is exploring a robotic solution designed for the radiological inspection of nuclear facilities undergoing decommissioning.

The robot enables accurate sensor positioning on walls and ceilings to perform remote measurements.

Objective: reduce personnel exposure to potentially hazardous environments and control operational costs.

From research to industry

TITANBOT brings together complementary expertise to advance cable-driven parallel robots toward concrete industrial applications.

The consortium brings together:

Scientific research and development

Assessment, technological maturation, and safety

Technological
integration

Industrial requirements and use case
validation

Scientific research and development

Assessment, technological maturation
and safety

Technological
integration

Industrial requirements and use case
validation

The project aims to advance technologies from TRL 3-4 to TRL 6-7, ahead of a second phase dedicated to prototyping industrialization and the exploration of new use cases.

news

TITANBOT at Global Industrie 2026

TITANBOT showcased its work at Global Industrie 2026, a flagship event for industrial innovation.

Developing cable-driven parallel robots for industry with the Titanbot project

Can cable-driven parallel robots be deployed in industry to reduce the physical strain of human labor? The Titanbot project brings together six partners to test this hypothesis and deliver field-applicable solutions.

Scientific publications

Discover publications from the TITANBOT teams dedicated to the design, control, and analysis of cable-driven parallel robots.

This innovation is supported by the ANR, as part of the France 2030 Robotics Transfer Challenge.

Project ANR-23-DMRO-0020

ANR Funding: €4.05M for phase 1 of the project.

Budget: €5.91M