Project Coordinator: Stéphane Caro (CNRS Research Director).
Team Members: Aditya Kapilavai, Sophie Rousseau, Mikael Arslan, Vincent Febrer, Arnaud Merrien, Christine Chevallereau, Philippe Wenger.
Team Members: Suranjana Bose, Wenlin Zhang, Marc Gouttefarde
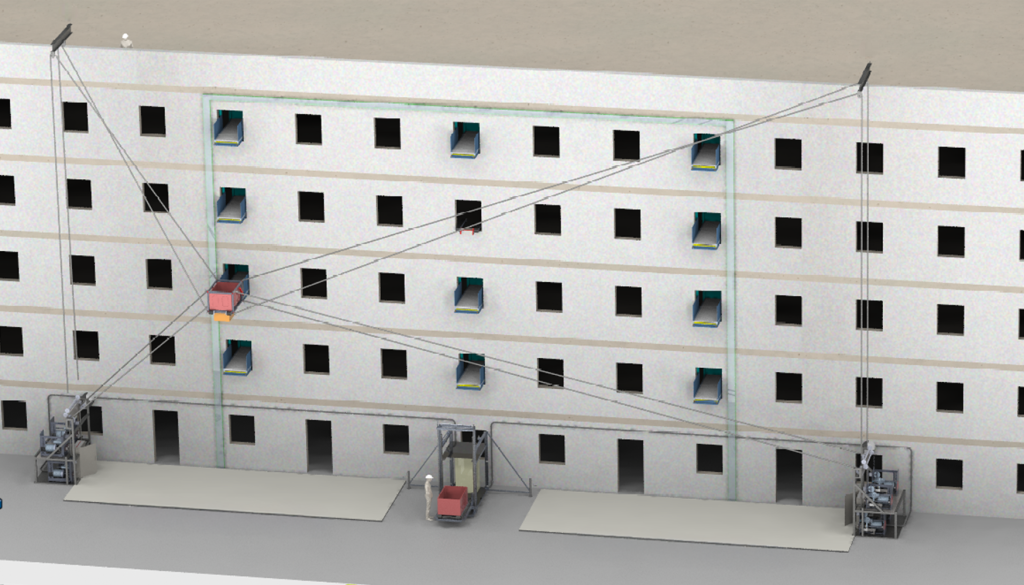
Use Case: Material handling and payload delivery along the facades of buildings under construction.
Contact / Lead: Christian Roda (Division Safety Officer).
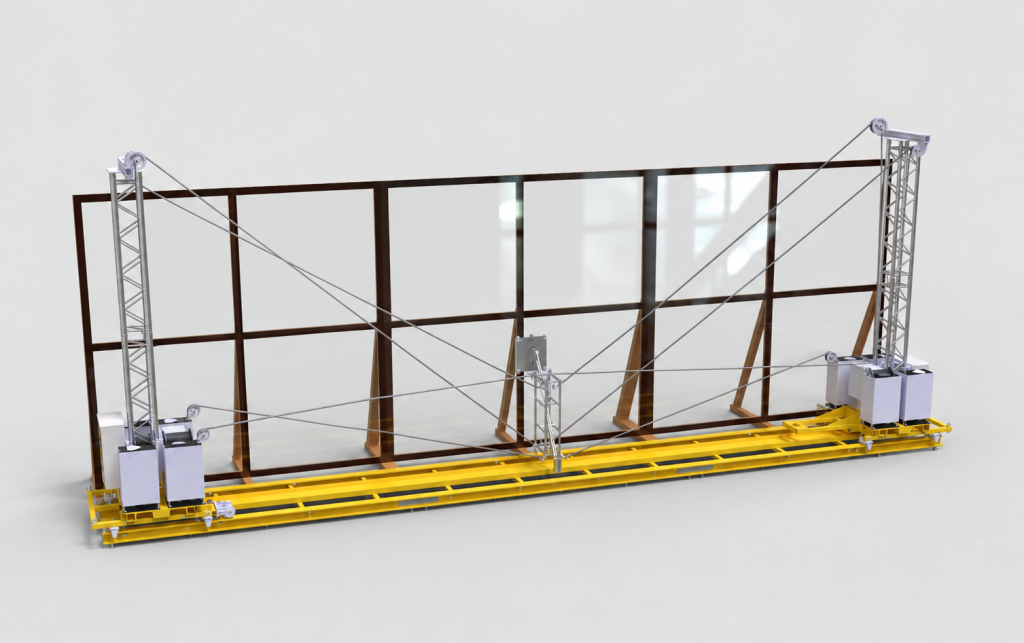
Use Case: Automated surface inspection and radiological monitoring during the decommissioning of nuclear facilities.
Contacts / Leads: Jean-François Thro (R&D Technical Manager), Stéphane Dogny.
Learn More
Role: Technology assessment and demonstrator development.
Team Members: Tahir Rasheed, Sylvain Le Queffelec, Guy Caverot, Viktor Vavra.
Role: Technology integrator responsible for engineering, mechanical design, and prototype industrialization readiness.
Team Members: Frédéric Le Hent, Nicolas Levaux.
Role: Technological evaluation, standardization efforts, and contribution to operator safety.
Team Members: Sylvain Acoulon, Collin Louison, Romane Fuvelle.
Contact / Lead: Nicolò Pedemonte
Contacts / Leads: Julien Cau (Illustrations and support)
State Support via France 2030.
Operated by: The ANR (French National Research Agency).
With additional support from: Bpifrance as well as the ROBOTEX 2.0 (ANR-10-EQPX-44-01) and TIRREX (ANR-21-ESRE-0015) research infrastructures.